A startup called Physicl has raised $10 million to build realistic digital worlds where robots can practice before they handle anything real. Inovia Capital led the seed round, which is an early round of funding. The company's bet is that a robot trained on better fake scenes will do better in real kitchens, shops and warehouses.
What Physicl is releasing
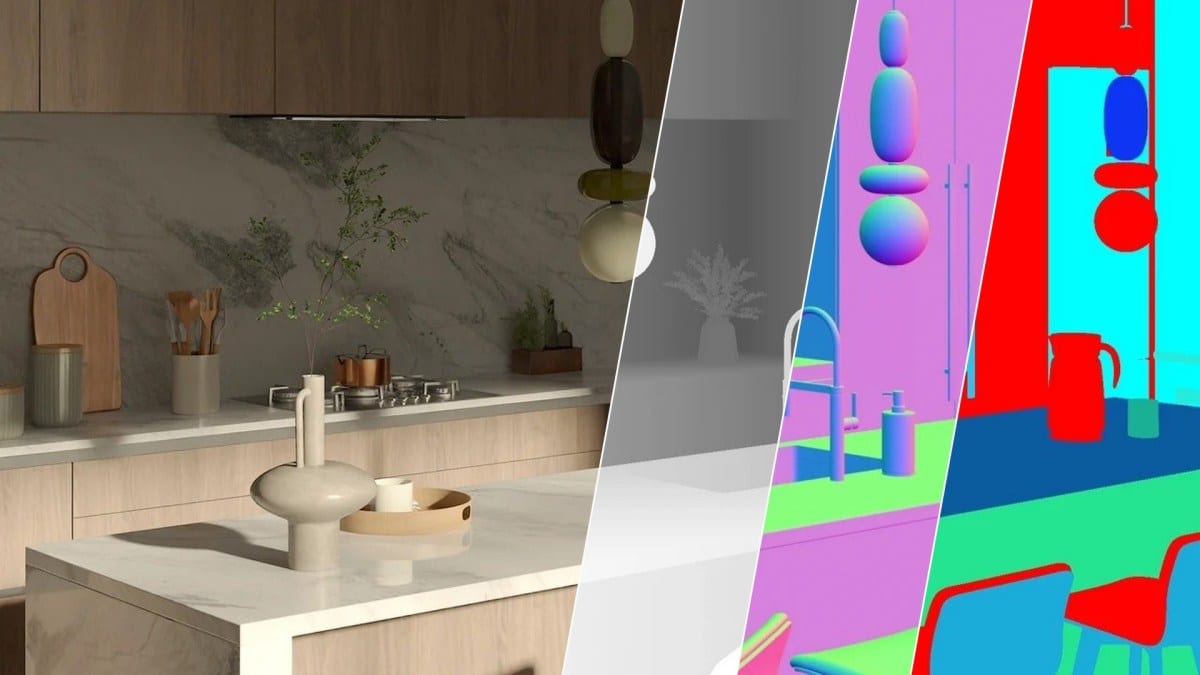
The first product is called Studio. It comes with 10,000 3D environments and 100,000 digital objects. Users can build scenes from those pieces and generate synthetic data, which means practice material made by a computer instead of collected in the real world.
The focus is on hard cases. One example is a robot that struggles to spot a cup on a cluttered counter or when the cup sits in shadow. Studio could generate many versions of that exact scene so the robot can train on it.
Why this problem is hard
Researchers building AI for robots have been frustrated by two things. Training on video has not paid off as hoped. Collecting data by having people remotely control robots is expensive.
Simulation looks like a way out. The catch is that a simulated world has to follow real-world physics, or the robot learns the wrong lessons. Closing that difference is known as the sim-to-real gap.
Where the technology came from
Founder and CEO Alex de Vigan spent the last decade building nfinite. That company helped brands and retailers make 3D models of their products to show online. Generative AI, the kind that creates images on request, pushed that business toward AI imagery.
De Vigan decided the old tools could serve a new purpose. They turn messy, incomplete real-world information into 3D scenes with correct shapes, materials and physics. He now wants to use that to train robots.
Early signs and open questions
SpAItial, a company that builds world models, was an early customer. Its tool creates 3D simulations from flat 2D images. Its CEO, Matthias Niessner, who is also a robotics professor at the Technical University of Munich, said preparing training data by hand takes a long time. He likes the idea of generating it automatically while a model trains.
Physicl is entering a crowded field. De Vigan himself called the space young and sometimes blurry. Other companies already collect, label or generate data for robot builders.
- Pricing for Studio was not shared.
- No customers beyond SpAItial were named.
- There are no results yet showing robots doing better in the real world.
- De Vigan's larger vision of feeding in trillions of images is a goal, not a product.
The takeawayPhysicl is betting that realistic digital practice worlds can make robots better with everyday objects, but real-world proof has not been shown yet.